Integrated Range
FLXBL60-300-ELE-M
Integrated BLDC servo motor with EtherCAT interface
Power
353 W
Rated Torque
0,65 Nm
Peak Torque
1,95 Nm
Rated Speed
5200 RPM

Technical Specifications
Reference Comparison
| Specifications | FLXBL60-300-ELE-N-M | FLXBL60-300-ELE-B-M |
|---|---|---|
| Technical Data | ||
| Rated voltage | 48 V | 48 V |
| Rated power | 353 W | 353 W |
| Rated speed | 5200 RPM | 5200 RPM |
| Rated current | 9,2 A | 9,2 A |
| Peak current | 27,6 A | 27,6 A |
| Rated torque | 0,65 Nm | 0,65 Nm |
| Peak torque | 1,95 Nm | 1,95 Nm |
| Torque constant | 0,07 Nm/A | 0,07 Nm/A |
| Voltage constant | 4,2 V/krpm | 4,2 V/krpm |
| Resistance line-line | 0,29 Ω | 0,29 Ω |
| Inductance line-line | 0,35 mH | 0,35 mH |
| Number of poles | 10 | 10 |
| Rotor moment of inertia | 0,39 kg.cm² | 0,39 kg.cm² |
| Flange | 60 mm | 60 mm |
| Overall length | 112,3 mm | 112,3 mm |
| Motor weight | 840 g | 1200 g |
| Controller & Interface | ||
| Main supply range | 12-75 VDC | 12-75 VDC |
| Nominal supply | 48 VDC | 48 VDC |
| Communication | EtherCAT, USB configuration | EtherCAT, USB configuration |
| Digital inputs | 3 opto-isolated, configurable | 3 opto-isolated, configurable |
| High-speed capture | 5 minimum pulse width in latch/capture mode µs | 5 minimum pulse width in latch/capture mode µs |
| Digital outputs | 2 opto-isolated outputs | 2 opto-isolated outputs |
| Output supply / current | 12-30 VDC, up to 30 mA | 12-30 VDC, up to 30 mA |
| Analog input | 1 differential, +/-10 V | 1 differential, +/-10 V |
| Analog resolution | 12 bit | 12 bit |
| STO input | 12-28.8, nominal 24 VDC | 12-28.8, nominal 24 VDC |
| Protection functions | Short-circuit, over-current, over/under-voltage | Short-circuit, over-current, over/under-voltage |
| Operating temperature | -10 to +40 °C | -10 to +40 °C |
| Humidity | <85, non-condensing %RH | <85, non-condensing %RH |
Mechanical Integration & Performance
2D Drawings and Curves
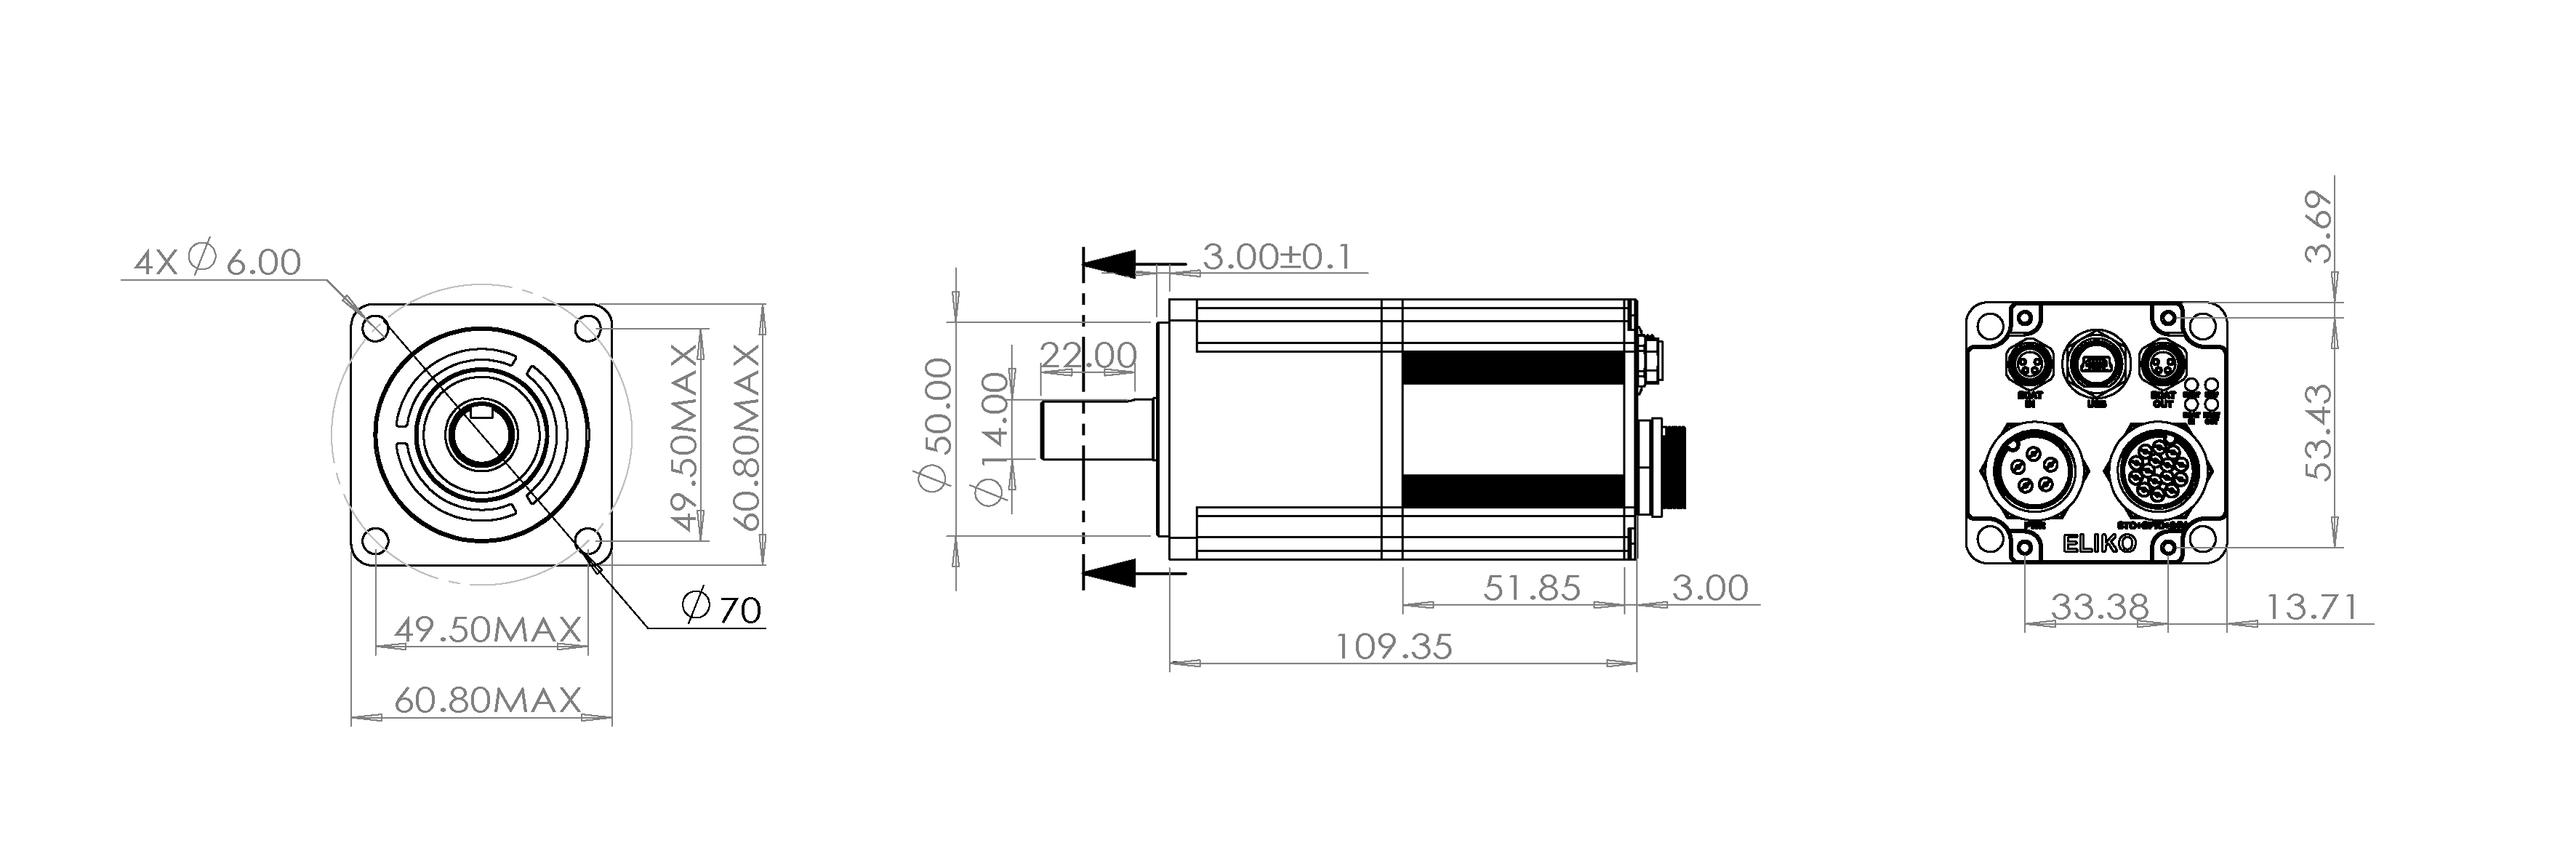
Dimensions
Mechanical 2D Drawing - FLXBL60-300-ELE-N-M
Dimensions
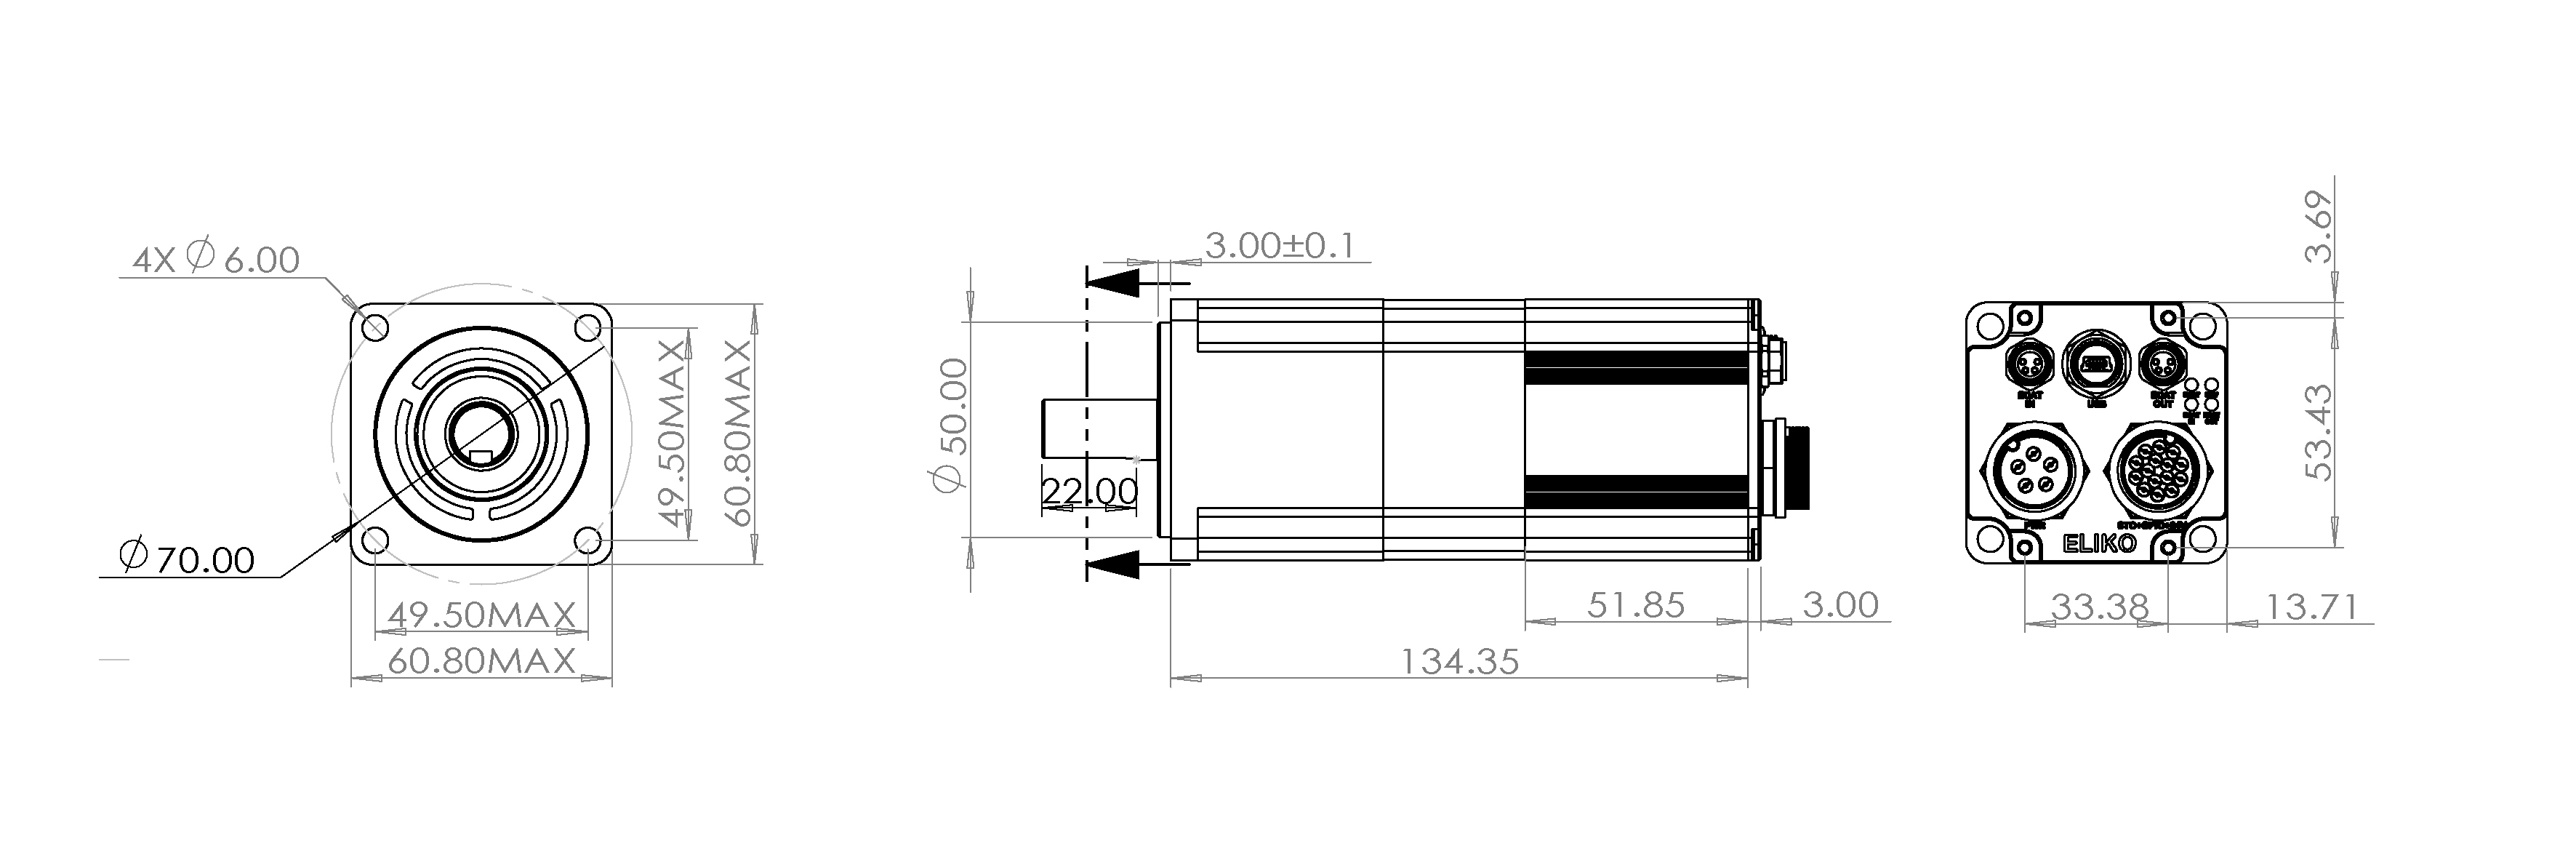
Mechanical 2D Drawing - FLXBL60-300-ELE-B-M
Performance
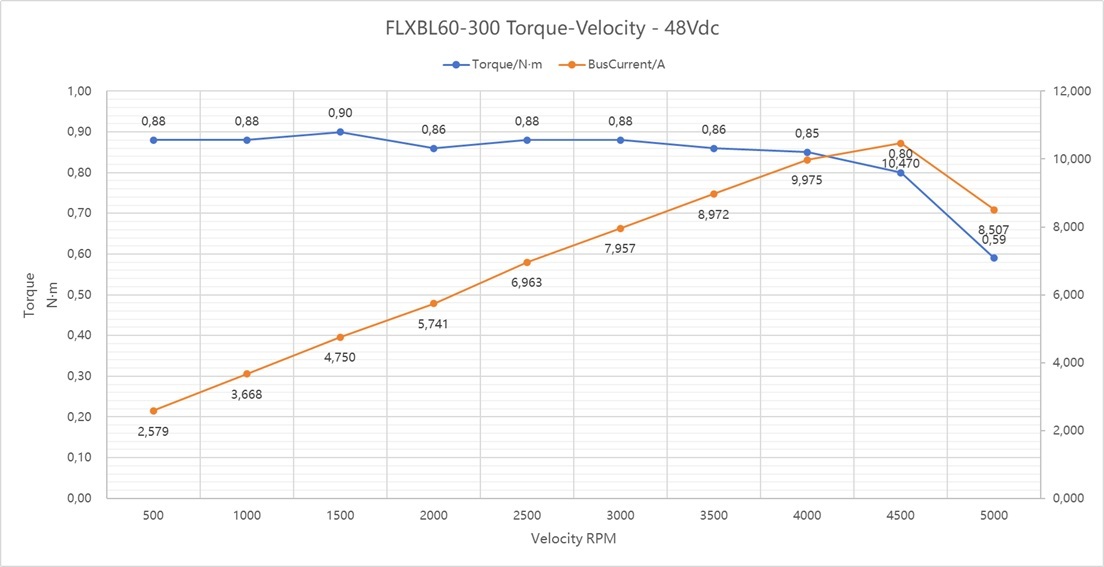
Torque / Speed Curves
Identification
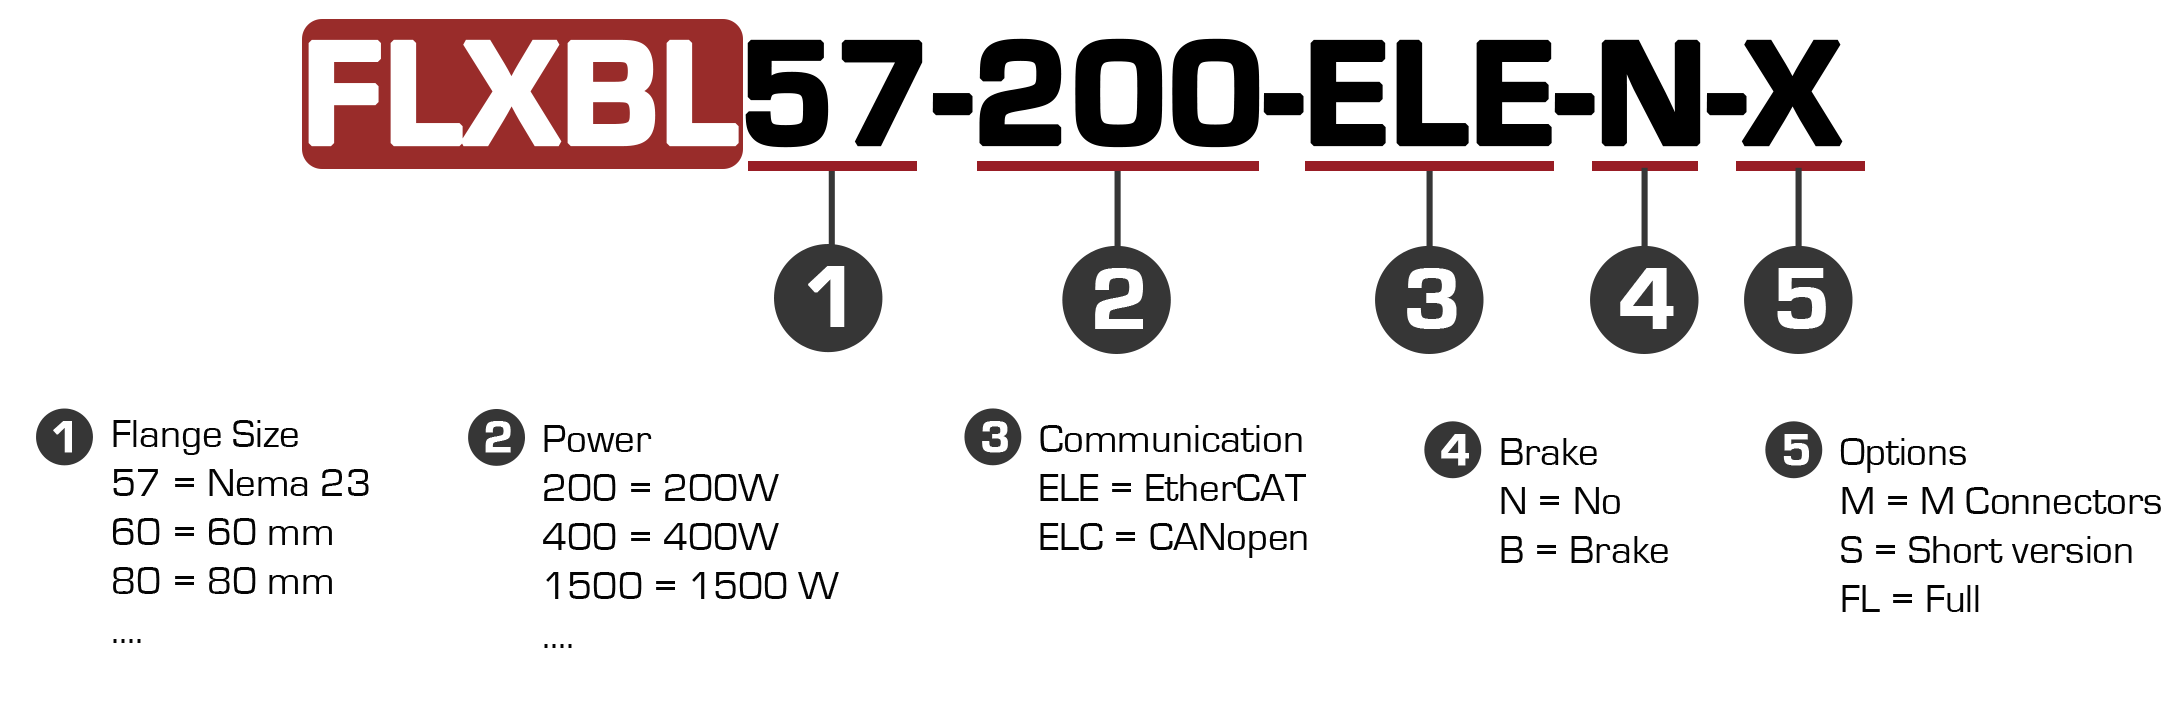
Part Numbering System